Application scope
- The application scope covers multi-format bottle group packing, programmatically changeable beverage packaging, and products suitable for vacuum or mechanical gripping.
Secondary Packaging and End of Line
The robotic case packer utilizes articulated industrial robots and specialized end-of-arm tooling to pick up collated bottle groups or packaging units and place them into corrugated cases according to programmed trajectories.
Project fit snapshot
Suitability depends on the product, container, output, hygienic route and connected equipment. Conditions outside the published scope require engineering review.
Technical content: fourth editionProject records shown below are project-specific references, not standard specifications.
The robotic case packer utilizes articulated industrial robots and specialized end-of-arm tooling to pick up collated bottle groups or packaging units and place them into corrugated cases according to programmed trajectories.
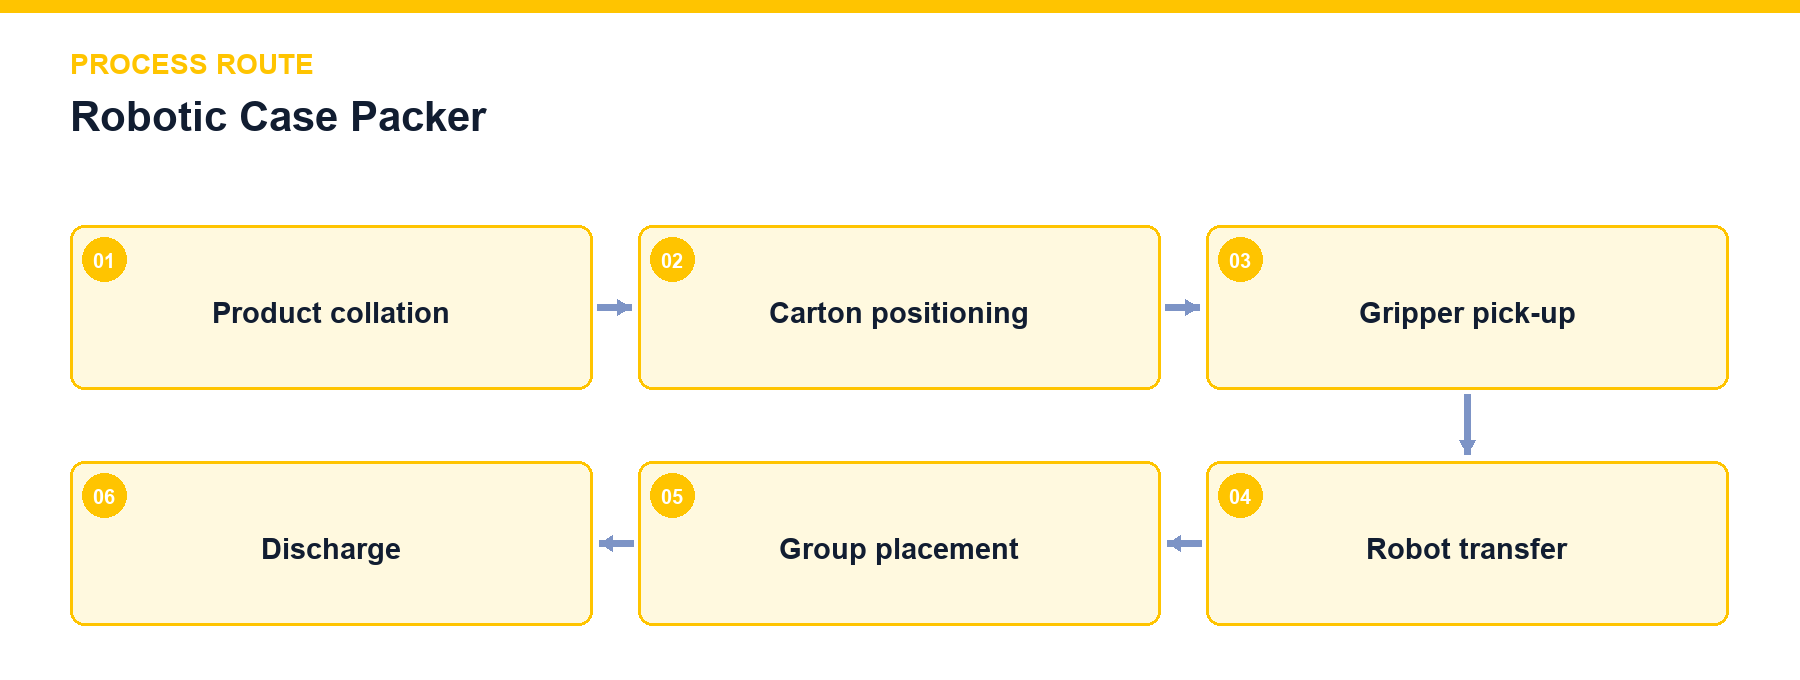
The robotic packing unit integrates product collation, empty carton positioning, industrial robots, custom EOOT, safety enclosures, and discharge conveyors. While robots provide programmable motion, system capability relies on stable product grouping, reliable gripping, and precise carton positioning. Grippers utilize vacuum, mechanical clamping, or hybrid configurations, taking into account total payload weight, bottle rigidity, label/cap positioning, allowable clamping pressure, and fall-safe handling. Multi-format production is achieved via software recipes, guide widths, pick/place coordinates, and tool exchanges, with changeover design ensuring operators verify recipe and mechanical alignment.
Scroll horizontally to see all table columns.
| Design Object | Technical Description |
|---|---|
| Infeed Collation | Forming stable product groups matching pick count, pitch, and orientation. |
| Gripper Selection | Choosing vacuum or mechanical clamping based on product surface, weight, rigidity, and pressure limits. |
| Robot Payload | Accounting for product, gripper, and dynamic acceleration forces during payload and reach verification. |
| Empty Carton Positioning | Maintaining carton squareness, bottom support, and stability during loading. |
| Trajectory and Timing | Coordinating pick, obstacle avoidance, placement, and return trajectories with upstream/downstream flow. |
| Safety Zones | Perimeter fencing, safety interlocks, emergency stops, and access protocols covering full motion ranges. |
| Error Recovery | Providing observable, step-by-step manual recovery routines for dropped bottles, vacuum loss, or misaligned cartons. |
Scroll horizontally to see all table columns.
| Component | Function |
|---|---|
| Infeed Collation Unit | Forms stable product arrays for robotic pick-up. |
| Articulated Robot Arm | Executes pick, transfer, and placement trajectories. |
| Specialized End-of-Arm Tooling | Utilizes mechanical, vacuum, or hybrid gripping. |
| Carton Conveyor and Positioning Unit | Stably holds empty cartons during loading. |
| Safety Enclosure | Isolates motion zones via fencing, safety door locks, and control circuits. |
Operation and control encompass product and carton positioning interlocks, gripper vacuum or clamping status confirmation, robot trajectory and station occupancy management, safety door and operator access protocols, and manual recovery/step-by-step operating modes.
Cleaning and maintenance require periodic replacement of vacuum suction cups, gripper fingers, and contact pads based on wear and contamination, energy isolation and mechanical drop-prevention measures prior to robot and gripper maintenance, routine inspection of position sensors, carton guides, and safety door interlocks, and low-speed, step-by-step trajectory verification following recipe or gripper changeovers.
Scroll horizontally to see all table columns.
| Input Parameter | Description |
|---|---|
| Product Specs | Dimensions, weight, packing matrix per carton, and gripping pressure limits. |
| Carton & Speed | Carton dimensions, target case speed, and infeed direction. |
| Changeover & Safety | Changeover quantity requirements, safety clearance, and maintenance access. |
Project reference only — not a standard specification.
Scroll horizontally to see all table columns.
| Project Description | Configuration / Parameter | Use Boundary |
|---|---|---|
| General Project Equipment Range | Articulated robotic case packer featuring programmable recipe selection, vacuum/mechanical gripper options, and integrated safety interlocking for multi-format lines | Project Equipment Range |
Grippers incorporate adjustable vacuum cups or compliant mechanical fingers with regulated gripping pressure sensors to ensure secure handling without container deformation.
Changeovers involve selecting the corresponding software recipe on the HMI, adjusting mechanical lane guides, and exchanging end-of-arm tooling when container dimensions change significantly.
Contact our automation engineering team to integrate a robotic case packer that maximizes flexibility and reduces changeover downtime in your packaging hall.
Discuss your project